Protected Member Functions | |
| _apply_horizontal_binning (self, spectrum) | |
| _check_for_random_error (self) | |
| _correct_bad_pixels (self, spectrum) | |
| _correct_ingaas_gain_and_offset (self, list[float] spectrum) | |
| Until support for even/odd InGaAs gain and offset have been added to the firmware, apply the correction in software. | |
| SpectrometerResponse | _get_code (self, int bRequest, int wValue=0, int wIndex=0, int wLength=64, str label="", int msb_len=None, int lsb_len=None) |
| _init_process_funcs (self) | |
| _post_connect (self) | |
| _read_eeprom (self) | |
| _read_eeprom_pages (self, first, count) | |
| _read_fpga_compilation_options (self) | |
| _read_pixel_correction_from_eeprom (self) | |
| _schedule_disconnect (self, exc) | |
| SpectrometerResponse | _send_code (self, int bRequest, int wValue=0, int wIndex=0, data_or_wLength=None, str label="", bool dry_run=False, bool retry_on_error=False, int success_result=0x00) |
| _set_laser_enable_immediate (self, bool flag) | |
| _to40bit (self, val) | |
| _wait_for_usb_available (self) | |
 Protected Member Functions inherited from wasatch.InterfaceDevice.InterfaceDevice | |
| _refresh_alerts (self) | |
| Incoming Sideline Messages. | |
Additional Inherited Members | |
| Protected Attributes inherited from wasatch.InterfaceDevice.InterfaceDevice | |
| _alerts = set() | |
| dict | _supported_message_queue_types |
Detailed Description
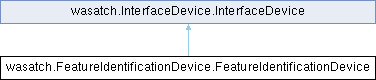
This is the basic implementation of our FeatureIdentificationDevice (FID)
spectrometer USB API as defined in ENG-0001.

This class is roughly comparable to Wasatch.NET's Spectrometer.cs.

This class is normally not accessed directly, but through the higher-level
abstraction WasatchDevice.

@see ENG-0001
Constructor & Destructor Documentation
◆ __init__()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.__init__ | ( | self, | |
| device_id, | |||
| message_queue = None, | |||
| alert_queue = None ) |
Instantiate a FeatureIdentificationDevice with from the given device_id.
@param message_queue [in] if provided, provides an outbound (from FID
       to WrapperWorker) queue for writing StatusMessage objects upstream
Member Function Documentation
◆ _apply_horizontal_binning()
|
protected |
◆ _check_for_random_error()
|
protected |
This function is provided to simulate random USB communication errors
during regression testing, and is normally a no-op.
◆ _correct_bad_pixels()
|
protected |
If a spectrometer has bad_pixels configured in the EEPROM, then average
over them in the driver.
Note this function modifies the passed array in-place, rather than
returning a modified copy.
@note assumes bad_pixels is previously sorted
◆ _correct_ingaas_gain_and_offset()
|
protected |
Until support for even/odd InGaAs gain and offset have been added to the firmware, apply the correction in software.
◆ _get_code()
|
protected |
- Note
- weird that so few calls to this function override the default wLength
- Todo
- consider adding retry logic as well
◆ _init_process_funcs()
|
protected |
Is it the expectation that all of these functions will return
SpectrometerResponse? If so, that should be made explicit.
◆ _post_connect()
|
protected |
Perform additional setup after instantiating FID device.
Split-out from physical / bus connect() to simplify MockSpectrometer.
◆ _read_eeprom()
|
protected |
◆ _read_eeprom_pages()
|
protected |
◆ _read_fpga_compilation_options()
|
protected |
◆ _read_pixel_correction_from_eeprom()
|
protected |
◆ _schedule_disconnect()
|
protected |
Something in the driver has caused it to request the controlling
application to close the peripheral.  The next time
WasatchDevice.acquire_data is called, it will pass a "poison pill" back
up the response queue.
Alternately, non-ENLIGHTEN callers can set "raise_exceptions" -> True for
in-process exception-handling.
◆ _send_code()
|
protected |
◆ _set_laser_enable_immediate()
|
protected |
The user has requested to update the laser firing state (on or off),
so apply the new laser state to the spectrometer immediately.

Because the ability to immediately disable a laser is a safety-related
feature (noting that truly safety-critical capabilities should be
implemented in hardware, and generally can't be robustly achieved through
Python scripts), this function takes the unusual step of looping over
multiple attempts to set the laser state until either the command succeeds,
or 3 consecutive failures have occured.

This behavior was added after a developmental, unreleased prototype was
found to occasionally drop USB packets, and was therefore susceptible to
inadvertently failing to disable the laser upon command.

@private (as callers are recommended to use set_laser_enable)
@param flag (Input) whether the laser should be on (true) or off (false)
@returns true if new state was successfully applied
◆ _to40bit()
|
protected |
Laser modulation and continuous-strobe commands take arguments in micro-
seconds as 40-bit values, where the least-significant 16 bits are passed
as wValue, the next-significant 16 as wIndex, and the most-significant
as a single byte of payload.  This function takes an unsigned integral
value (presumably microseconds) and returns a tuple of wValue, wIndex
and a buffer to pass as payload.
◆ _wait_for_usb_available()
|
protected |
Wait until any enforced USB packet intervals have elapsed. This does
nothing in most cases - the function is normally a no-op.
However, if the application has defined min/max_usb_interval_ms (say
(20, 50ms), then pick a random delay in the defined window (e.g. 37ms)
and sleep until it has been at least that long since the last USB
exchange.
The purpose of this function was to wring-out some early ARM micro-
controllers with apparent timing issues under high-speed USB 2.0, to see
if communications issues disappeared if we enforced a communication
latency from the software side.
◆ apply_edc()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.apply_edc | ( | self, | |
| spectrum ) |
Use optically black pixels for electrical dark correction (EDC).

@par IMX385LQR-C datasheet (p8)

@verbatim
Pixels    Count Description
0-3       4     OB side ignored area                <-- using this
4-7       4     Effective pixel side ignored area
8-15      8     Effective margin for color processing
16-1935   1920  Recording pixel area
1936-1944 9     Effective margin for color processing
1945-1948 4     Effective pixel side ignored area
1949-1951 3     Dummy
@endverbatim

@note that this is called BEFORE horizontal binning, so should still work
      even with BIN_4X2

@todo we might want to make buffer length configurable, either in spectra
      or by time (consider 10ms vs 1sec integration time)
◆ can_laser_fire()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.can_laser_fire | ( | self | ) |
@note only works on XS, and FX2-based spectrometers with FW >= 10.0.0.11
@note on XS, opcode returns 0x00 (false) or 0x08 (true)
@returns True if there is a laser and either the interlock is
         closed (in firing position), or there is no readable
         interlock
◆ clear_regions()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.clear_regions | ( | self | ) |
◆ connect()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.connect | ( | self, | |
| retries = 0 ) |
Connect to the device and initialize basic settings.
@warning this causes a problem in non-blocking mode (WasatchDeviceWrapper)
on MacOS
◆ disconnect()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.disconnect | ( | self | ) |
◆ generate_timeout_ms()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.generate_timeout_ms | ( | self | ) |
◆ get_acc_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_acc_state | ( | self | ) |
◆ get_actual_frames()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_actual_frames | ( | self | ) |
◆ get_actual_integration_time_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_actual_integration_time_us | ( | self | ) |
◆ get_ambient_temperature_degC()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ambient_temperature_degC | ( | self | ) |
◆ get_ambient_temperature_degC_arm()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ambient_temperature_degC_arm | ( | self | ) |
◆ get_ambient_temperature_degC_gen15()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ambient_temperature_degC_gen15 | ( | self | ) |
@see https://www.nxp.com/docs/en/data-sheet/LM75B.pdf
◆ get_analog_input_value()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_analog_input_value | ( | self | ) |
◆ get_analog_output_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_analog_output_state | ( | self | ) |
◆ get_area_scan()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_area_scan | ( | self | ) |
@returns Reading(spectrum, AreaScanImage(data=nd_array))

It's important to understand that Hamamatsu and XS area scan features
are architected differently in several respects.

@par Hamamatsu Area Scan

Full-frame Hamamatsu area scans are collected and returned in a single
blocking call. This is possible because:

- the frame is only 69 lines (6% of a 1080p image)
- FX2-based 110008 boards use 480 mbps High-Speed USB (40x faster than
  12 mbps Full-Speed)
- CCDs are more sensitive as CMOS, allowing shorter integration times
- Hamamatsu sensors don't have the 32ms min per-frame LVDS transfer time
- Hamamatsu sensors allow vertical shifting and horizontal-readout to be
  delayed by the FPGA until the previous line has been pushed to the FX2,
  allowing every line in a frame to be sequentially read and pushed (vs
  IMX385 free-running frame times forcing one line/frame)
- the FX2 internally generates subsequent ACQUIRE signals to the FPGA
  after each line has been read-out from the USB buffers to host, reducing
  the number of EP0 control messages

Due to the above, the Hamamatsu area scan can be executed much faster
than an IMX385 area scan, and is considered fast enough to "block" on
the full frame.

Therefore, a single blocking call to get_area_scan_hamamatsu() will
return a complete area scan frame in roughly the following time:

    INTEG_MS + TICK_US x LINES x (PIXELS + 1)

where:
    INTEG_MS is current integration time
    LINES    is 69 for most Hamamatsu CCDs (128 for C0)
    PIXELS   is 1044 or 2068 as appropriate (physical, not active)
    TICK_US  is 2µs or 4µs as appropriate (depends on clock speed at
             which FPGA 'ticks' the CCD)

"PIXELS + 1" represents the 1 tick required for each line's vertical
shift, plus PIXELS ticks for the horizontal read-out.

@par XS Area Scan

In contrast, as long as our IMX385 sensor is controlled in "main mode,"
via Spartan6 with no additional DDR memory, over LVDS, the XS image scan
must be read line-by-line, where each line requires a separate full-frame
acquisition (32ms minimum latency).

Therefore, a full area scan of a 1080p detector would take AT LEAST 32ms
x 1080 lines = 35sec just for LVDS readout to the FPGA. The 1080 ACQUIRE
commands would stretch that out further. Over 12mbps Full-Speed USB, the
entire process comes to something like 2.5 MINUTES operationally.

Therefore, a blocking call to get_area_scan_xs() will return A SINGLE LINE
of an ONGOING area scan. This allows ENLIGHTEN to appear "responsive"
during the area scan process, updating its graphical area scan image in
real-time as each line is received.

To further speed the process, the XS FPGA will only return lines within
the configured vertical ROI, so if a vertical ROI of (300, 500) is config-
ured, the area scan image will only comprise 200 lines rather than the
full 1080.

Also, since each call to this function will only return a single line,
and the FPGA will automatically "roll-over" the current line index after
coming to the configured stop_line (returning to the configured start_line),
this function does not have a concept of "stopping" or "finishing" a frame;
subsequent calls will just keep sending out additional lines, until the
spectrometer is taken out of area scan mode.
◆ get_area_scan_hamamatsu()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_area_scan_hamamatsu | ( | self | ) |
@returns Reading(spectrum, AreaScanImage(data=nd_array))
◆ get_area_scan_xs()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_area_scan_xs | ( | self | ) |
@returns Reading(spectrum, AreaScanImage(data=nd_array))
@see sensor docs in IMX385.py

Physically, the largest area scan image ENLIGHTEN or WPSC can generate is
(1952, 1097).
◆ get_battery_charging()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_battery_charging | ( | self | ) |
◆ get_battery_percentage()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_battery_percentage | ( | self | ) |
◆ get_battery_register()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_battery_register | ( | self, | |
| int | reg ) |
◆ get_battery_state_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_battery_state_raw | ( | self | ) |
Retrieves the raw battery reading and then caches it for 1 sec
◆ get_ble_firmware_version()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ble_firmware_version | ( | self | ) |
◆ get_ccd_sensing_threshold()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ccd_sensing_threshold | ( | self | ) |
◆ get_ccd_threshold_sensing_mode()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_ccd_threshold_sensing_mode | ( | self | ) |
◆ get_cont_strobe_delay_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_cont_strobe_delay_us | ( | self | ) |
◆ get_cont_strobe_period_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_cont_strobe_period_us | ( | self | ) |
◆ get_cont_strobe_repeat_count()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_cont_strobe_repeat_count | ( | self | ) |
◆ get_cont_strobe_width_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_cont_strobe_width_us | ( | self | ) |
◆ get_dac()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_dac | ( | self, | |
| int | dacIndex = 0 ) |
◆ get_detector_gain()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_gain | ( | self, | |
| bool | update_session_eeprom = False ) |
Read the device stored gain.  Convert from binary "half-precision" float.
- 1st byte (LSB) is binary encoded: bit 0 = 1/2, bit 1 = 1/4, bit 2 = 1/8 etc.
- 2nd byte (MSB) is the integral part to the left of the decimal
E.g., 231 dec == 0x01e7 == 1.90234375
◆ get_detector_gain_odd()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_gain_odd | ( | self, | |
| bool | update_session_eeprom = False ) |
◆ get_detector_offset()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_offset | ( | self | ) |
◆ get_detector_offset_odd()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_offset_odd | ( | self | ) |
◆ get_detector_tec_setpoint_degC()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_tec_setpoint_degC | ( | self | ) |
◆ get_detector_tec_setpoint_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_tec_setpoint_raw | ( | self | ) |
◆ get_detector_temperature_degC()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_temperature_degC | ( | self, | |
| float | raw = None ) |
◆ get_detector_temperature_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_detector_temperature_raw | ( | self | ) |
- Note
- big-endian, reverse of get_laser_temperature_raw
◆ get_discretes_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_discretes_enabled | ( | self | ) |
- Todo
- find out opcode
◆ get_external_trigger_output()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_external_trigger_output | ( | self | ) |
◆ get_fan_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_fan_enabled | ( | self | ) |
◆ get_fpga_configuration_register()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_fpga_configuration_register | ( | self, | |
| str | label = "" ) |
◆ get_fpga_firmware_version()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_fpga_firmware_version | ( | self | ) |
◆ get_gpio_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_gpio_state | ( | self | ) |
◆ get_high_gain_mode_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_high_gain_mode_enabled | ( | self | ) |
◆ get_integration_time_ms()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_integration_time_ms | ( | self | ) |
◆ get_lamp_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_lamp_enabled | ( | self | ) |
◆ get_laser_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_enabled | ( | self | ) |
◆ get_laser_interlock()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_interlock | ( | self | ) |
laser interlock
Legacy wrapper over can_laser_fire.
◆ get_laser_power_attenuator()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_power_attenuator | ( | self | ) |
◆ get_laser_tec_mode()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_tec_mode | ( | self | ) |
The current opcode (0x85) seems to be actually returning
GET_LASER_TEC_ENABLED, not GET_LASER_TEC_MODE.
◆ get_laser_temperature_degC()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_temperature_degC | ( | self, | |
| raw = None ) |
Laser temperature conversion doesn't use EEPROM coeffs at all.
- IPS
Some Wasatch SML products use an IPS Wavelength-Stabilized TO-56 laser, which internally uses a Betatherm 10K3CG3 thermistor.
The official IPS conversion from thermistor resistance (in ohms) to degC is:
1 / (   C1
      + C2 * ln(ohms)
      + C3 * pow(ln(ohms), 3)
    )
- 273.15

Where: C1 = 0.00113
       C2 = 0.000234
       C3 = 8.78e-8
That said, on XS the IPS thermistor then goes through a MAX1978ETM-T TEC IC which buffers the thermistor voltage. This requires the additional empirically-determined static conversion captured below.
Regrettably, the laser thermistor voltage on 110280 boards overflows the ADC range, so we don't currently have valid laser temperature read-out with those PCBs.
- Ondax MML
On MML units using the Ondax OEM Module, the cable to the 220060 does not seem to pass-through the thermistor pin, so we don't have laser temperature read-out on those, either. (Nor photodiode...)
- RealLight
RealLight SML thermistors use the following resistance and beta:
Thermistor Rt (kΩ / β(25°C)): 10±5% / 3450
Therefore you can convert the raw thermistor ADC reading to degrees Celsius:
Convert raw ADC to voltage:
voltage = 2.5 * raw / 4096
Convert voltage to resistance (assuming 2.5v reference)
resistance = 21450.0 * voltage / (2.5 - voltage)
Convert resistance to Kelvin:
1/T = (1/T0) + (1/β) * ln(R/R0) 1 = T((1/T0) + (1/β) * ln(R/10)) T = 1/((1/T0) + (1/β) * ln(R/10))
Where:
T: is the temperature in Kelvin T0: is a reference temperature (usually 25°C or 298.15K) β: is the beta value of the thermistor (a constant indicating the relationship between resistance and temperature) R: is the measured resistance of the thermistor R0: is the resistance of the thermistor at the reference temperature T0
Kelvin = 1/((1/298.15) + (1/3450) * ln(resistance/10))
Convert Kelvin to degrees Celsius:
degC = Kelvin - 273.15
- Parameters
-
raw the value read from the thermistor's 12-bit ADC (can be uint12 or SpectrometerResponse)
◆ get_laser_temperature_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_temperature_raw | ( | self | ) |
@note little-endian, reverse of get_detector_temperature_raw
◆ get_laser_temperature_setpoint_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_temperature_setpoint_raw | ( | self | ) |
- Note
- never used, provided for OEM
◆ get_laser_warning_delay_sec()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_warning_delay_sec | ( | self | ) |
◆ get_laser_watchdog_sec()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_laser_watchdog_sec | ( | self | ) |
◆ get_line()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_line | ( | self, | |
| trigger = True, | |||
| auto_raman_params = None ) |
◆ get_microcontroller_firmware_version()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_microcontroller_firmware_version | ( | self | ) |
◆ get_microcontroller_serial_number()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_microcontroller_serial_number | ( | self | ) |
◆ get_mod_delay_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_delay_us | ( | self | ) |
◆ get_mod_duration_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_duration_us | ( | self | ) |
◆ get_mod_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_enabled | ( | self | ) |
◆ get_mod_linked_to_integration()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_linked_to_integration | ( | self | ) |
◆ get_mod_period_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_period_us | ( | self | ) |
◆ get_mod_width_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_mod_width_us | ( | self | ) |
◆ get_opt_actual_integration_time()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_actual_integration_time | ( | self | ) |
◆ get_opt_area_scan()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_area_scan | ( | self | ) |
◆ get_opt_cf_select()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_cf_select | ( | self | ) |
◆ get_opt_data_header_tab()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_data_header_tab | ( | self | ) |
◆ get_opt_has_laser()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_has_laser | ( | self | ) |
◆ get_opt_horizontal_binning()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_horizontal_binning | ( | self | ) |
◆ get_opt_integration_time_resolution()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_integration_time_resolution | ( | self | ) |
◆ get_opt_laser_control()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_opt_laser_control | ( | self | ) |
Laser commands.
◆ get_poll_status()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_poll_status | ( | self | ) |
◆ get_power_connection_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_power_connection_state | ( | self | ) |
◆ get_raman_delay_ms()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_raman_delay_ms | ( | self | ) |
◆ get_raman_mode_enabled_NOT_USED()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_raman_mode_enabled_NOT_USED | ( | self | ) |
- Note
- not called by ENLIGHTEN
- Warning
- conflicts with GET_SELECTED_LASER
◆ get_scans_to_average()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_scans_to_average | ( | self | ) |
◆ get_secondary_adc_calibrated()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_secondary_adc_calibrated | ( | self, | |
| float | raw = None ) |
◆ get_secondary_adc_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_secondary_adc_raw | ( | self | ) |
◆ get_selected_adc()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_selected_adc | ( | self | ) |
◆ get_selected_laser()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_selected_laser | ( | self | ) |
◆ get_sensor_line_length()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_sensor_line_length | ( | self | ) |
◆ get_shutter_open()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_shutter_open | ( | self | ) |
◆ get_spectrum()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_spectrum | ( | self, | |
| trigger = True, | |||
| auto_raman_params = None ) |
Send "acquire", then immediately read the bulk endpoint(s).
Probably the most important method in this class.

@param trigger (Input) send an initial ACQUIRE
@param auto_raman_params (Input) if present, use VR_ACQUIRE_AUTO_RAMAN
         rather than the usual VR_ACQUIRE_CCD

@returns a SpectrometerResponse in all instances. response.data should
         contain the spctrum on success, or None for other cases (check
         error_msg). response.data may be None when it times-out while
         waiting for an external trigger (interpret as, "didn't find any
         fish this time, try again in a bit")
@throws exception on timeout (unless external triggering enabled)
◆ get_strobe_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_strobe_enabled | ( | self | ) |
a literal pass-through to get_laser_enabled()
◆ get_tec_enabled()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_tec_enabled | ( | self | ) |
◆ get_trigger_delay()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_trigger_delay | ( | self | ) |
◆ get_trigger_source()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_trigger_source | ( | self | ) |
Read the trigger source setting from the device.
- 0 = internal
- 1 = external
Use caution when interpreting the larger behavior of the device as ARM and FX2 implementations differ as of 2017-08-02
- Note
- never called by ENLIGHTEN - provided for OEMs
◆ get_upper_code()
| SpectrometerResponse wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_upper_code | ( | self, | |
| int | wValue, | ||
| int | wIndex = 0, | ||
| int | wLength = 64, | ||
| str | label = "", | ||
| int | msb_len = None, | ||
| int | lsb_len = None ) |
◆ get_vr_continuous_ccd()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_vr_continuous_ccd | ( | self | ) |
◆ get_vr_num_frames()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.get_vr_num_frames | ( | self | ) |
◆ has_linearity_coeffs()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.has_linearity_coeffs | ( | self | ) |
At least one linearity coeff is other than 0 or -1 (and no NaN).

Public because used by wasatch-shell.
◆ i2c_write()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.i2c_write | ( | self, | |
| address, | |||
| buf, | |||
| label = "" ) |
◆ is_laser_firing()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.is_laser_firing | ( | self | ) |
Check if the laser actually IS firing, independent of laser_enable or
can_laser_fire.

@returns SpectrometerResponse
◆ is_sensor_stable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.is_sensor_stable | ( | self | ) |
◆ require_throwaway()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.require_throwaway | ( | self, | |
| flag ) |
◆ reset()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.reset | ( | self, | |
| * | args ) |
◆ reset_area_scan_frame()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.reset_area_scan_frame | ( | self | ) |
◆ reset_fpga()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.reset_fpga | ( | self | ) |
(end of laser commands)
◆ reset_scan_averaging()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.reset_scan_averaging | ( | self, | |
| arg ) |
◆ select_adc()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.select_adc | ( | self, | |
| int | n ) |
◆ set_acc_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_acc_state | ( | self, | |
| XSAccState | acc_state ) |
◆ set_accessory_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_accessory_enable | ( | self, | |
| bool | flag ) |
- Todo
- change opcode (conflicts with GET_DETECTOR_START_LINE)
◆ set_analog_output_mode()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_analog_output_mode | ( | self, | |
| tuple[bool, int] | value ) |
- Parameters
-
value (Input) tuple of (bool enable, int mode)
◆ set_analog_output_value()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_analog_output_value | ( | self, | |
| int | value ) |
◆ set_area_scan_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_area_scan_enable | ( | self, | |
| flag ) |
Historically, this opcode moved around a bit. It is currently 0xeb, which
conflicts with CF_SELECT.  At one point it was 0xe9, which conflicted with
LASER_RAMP_ENABLE.
◆ set_area_scan_line_count()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_area_scan_line_count | ( | self, | |
| n ) |
◆ set_area_scan_line_interval()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_area_scan_line_interval | ( | self, | |
| n ) |
◆ set_area_scan_line_step()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_area_scan_line_step | ( | self, | |
| n ) |
◆ set_cont_strobe_delay_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_cont_strobe_delay_us | ( | self, | |
| float | us ) |
◆ set_cont_strobe_period_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_cont_strobe_period_us | ( | self, | |
| float | us ) |
MZ: untested
◆ set_cont_strobe_repeat_count()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_cont_strobe_repeat_count | ( | self, | |
| int | value ) |
◆ set_cont_strobe_settings()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_cont_strobe_settings | ( | self, | |
| XSContinuousStrobe | cont_strobe ) |
◆ set_cont_strobe_width_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_cont_strobe_width_us | ( | self, | |
| float | us ) |
◆ set_detector_gain()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_gain | ( | self, | |
| float | gain ) |
Note that this is used for detector types, including:
- Hamamatsu silicon (S16010-*, S16011-*, etc)
- Hamamatsu InGaAs (G9214 etc)
- Sony IMX (IMX385 etc)
It is important to understand that the UNIT of this value changes between Hamamatsu and IMX detectors, but the DATATYPE does not.
Reasonable gain levels for Hamamatsu are a floating-point scalar, literally used to scale (gain) the signal, and are usually in the range (0.8 .. 1.2) or thereabouts.
Reasonable levels for IMX sensors are in dB and vary by detector, but are usually in the range (0.0 .. 31.0), with exactly 0.1dB precision. The spectrometer's FW will round to the nearest setting (1.23 will be rounded to 1.2). IMX sensors switch from "analog gain" to "digital gain" above a given threshold...on the IMX123, analog gain is 0.0 - 31.0, and digital is 31.1 - 72.0 (I think).
- Todo
- we should probably track runtime hardware gain in SpectrometerState, not EEPROM
◆ set_detector_gain_odd()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_gain_odd | ( | self, | |
| float | gain ) |
◆ set_detector_offset()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_offset | ( | self, | |
| int | value ) |
◆ set_detector_offset_odd()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_offset_odd | ( | self, | |
| int | value ) |
◆ set_detector_roi()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_roi | ( | self, | |
| list[float] | args, | ||
| bool | store = True ) |
Note this only sends the ROI downstream to the spectrometer (and stores
it in DetectorRegions).  If you want to update the wavecal and store
the "selected" region index, use set_region() instead (which calls this).

You should use set_region() if you are selecting one of the standard
regions already configured on the EEPROM.  You should use set_detector_roi()
if you're making ad-hoc ROIs which aren't configured on the EEPROM.

@param args: either a DetectorROI or a tuple of (region, y0, y1, x0, x1)
◆ set_detector_tec_setpoint_degC()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_tec_setpoint_degC | ( | self, | |
| float | degC ) |
Attempt to set the CCD cooler setpoint. Verify that it is within an
acceptable range. Ideally this is to prevent condensation and other
issues. This value is a default and is hugely dependent on the
environmental conditions.
◆ set_detector_timeout_sec()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_detector_timeout_sec | ( | self, | |
| sec ) |
◆ set_dfu_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_dfu_enable | ( | self | ) |
Puts ARM-based spectrometers into Device Firmware Update (DFU) mode.
@warning reflashing spectrometer firmware without specific instruction and
support from Wasatch Photonics will void your warranty
◆ set_etalon_correction_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_etalon_correction_enable | ( | self, | |
| flag ) |
◆ set_fan_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_fan_enable | ( | self, | |
| bool | flag ) |
◆ set_gpio_state()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_gpio_state | ( | self, | |
| XSGPIOState | gpio_state ) |
◆ set_high_gain_mode_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_high_gain_mode_enable | ( | self, | |
| bool | flag ) |
CF_SELECT is configured using bit 2 of the FPGA configuration register 0x12.
This bit can be set using vendor commands 0xeb to SET and 0xec to GET. Note that the set command is expecting a 5-byte unsigned value, the highest byte of which we pass as part of an 8-byte buffer. Not sure why.
◆ set_ingaas_correction_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_ingaas_correction_enable | ( | self, | |
| flag ) |
◆ set_integration_time_ms()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_integration_time_ms | ( | self, | |
| float | ms ) |
Send the updated integration time in a control message to the device
@warning disabled EEPROM range-checking by customer
     request; range limits in EEPROM are defined as 16-bit
     values, while integration time is actually a 24-bit value,
     such that the EEPROM is artificially limiting our range.

@todo SiG needs to wait 20ms + 8 frames for stabilization.
◆ set_lamp_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_lamp_enable | ( | self, | |
| bool | flag ) |
◆ set_laser_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_enable | ( | self, | |
| bool | flag ) |
Turn the laser on or off.
If laser power hasn't yet been externally configured, applies the default
of full-power.  The new state will be applied immediately.
@param flag (Input) bool (True turns laser on, False turns laser off)
@returns whether the new state was applied
◆ set_laser_power_attenuator()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_attenuator | ( | self, | |
| value ) |
digital pot on 220250 Rev4A+
◆ set_laser_power_high_resolution()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_high_resolution | ( | self, | |
| bool | flag ) |
Sets whether the PWM pulse period is 1000µs (high-resolution, default) or 100µs (low-resolution, legacy).
- Parameters
-
flag (Input) True for 1000µs PWM period (high-resolution, default), False for 100µs (low-resolution)
Laser power is controlled via PWM (Pulse Width Modulation), essentially a square wave whose "duty cycle" (high vs low), expressed as a percentage, represents the amount of time the laser is actually firing. If the duty cycle is 33%, the laser will be firing 1/3 of the time, representing approximately one-third of "full power".
(It's not "exactly" one-third because the laser needs a moment to stablize when energized, and that "start-up" instability is increased when you're constantly pulsing the laser on-and-off.)
This function is used to determine the LENGTH (period) of that PWM square wave. Because the laser's PWM parameters are all specified in microseconds (µs), a longer period allows greater precision (resolution) in specifying the duty cycle.
Historically, Wasatch spectrometers used a PWM period of 100µs, meaning the pulse width (time each wave was high) could only be set from 1-99µs, giving an essential laser power resolution of 1%. That behavior can be restored by setting this value False.
More recently, we've increased the default PWM pulse period to 1000µs (1ms). Since the pulse width is still set in µs, that allows an effective laser power resolution of 0.1%. This is the new default, and can be explicitly requested by setting this value to True.
- Warning
- Note that this function is provided for cases where the laser power is set as a percentage. When setting laser power through milliWatts, using the onboard laser power calibration, it is important to use the same resolution as was in effect when the calibration was generated. All Wasatch laser power calibrations are generated in "high-resolution," so this function SHOULD NOT be set "False" (low-res) if setting laser power in mW.
◆ set_laser_power_mW()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_mW | ( | self, | |
| int | mW_in ) |
◆ set_laser_power_perc()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_perc | ( | self, | |
| float | value_in, | ||
| bool | set_in_perc = True ) |
- Todo
- support floating-point value, as we have a 12-bit ADC and can provide a bit more precision than 100 discrete steps (goal to support 0.1 - .125% resolution)
◆ set_laser_power_perc_immediate()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_perc_immediate | ( | self, | |
| float | value ) |
Sets laser power (modulated pulse width) which will be used next time the laser is turned on (or changed immediately, if the laser is already enabled).
Laser power is determined by a combination of the pulse width, period and modulation being enabled. There are many combinations of these values that will produce a given percentage of the total laser power through pulse width modulation. There is no 'get laser power' control message on the device.
Some of the goals of Enlighten are for it to be stable, and a reason we have sales. During spectrometer builds, it was discovered that the laser power settings were not implemented. During the implementation process, it was discovered that the laser modulation, pulse period and pulse width commands do not conform to specification. Where you can set integration time 100 ms with the command:
device.ctrl_transfer(bmRequestType=device_to_host, bRequest=0xDB, wValue=100, wIndex=0, data_or_wLength=0)
The laser pulse period must be set where the wValue and data_or_wLength parameters are equal. So if you wanted a pulse period of 100, you must specify the value in both places:
... wValue=100, data_or_wLength=100) ...
This in turn implies that the legacy firmware has a long masked issue when reading the value to update from the data_or_wLength parameter instead of the wValue field. This is only accurate for the laser modulation related functions.
This is backed up by the Dash v3 StrokerControl DLL implementation. It was discovered that the StrokerControl DLL sets the wValue and data or wLength parameters to the same value at every control message write.
The exciting takeaway here is that Enlighten is stable enough. Turning the laser on with the data or wLength parameter not set correctly will cause a hardware failure and complete device lockup requiring a power cycle.
fid: CRITICAL Hardware Failure FID Send Code Problem with ctrl transfer: [Errno None] 11
Unlike Dash which may lockup and require killing the application, Enlighten does not lock up. The Enlighten code base has now been used to unmask an issue that has been lurking with our legacy firmware for close to 6 years. We've detected this out of specification area of the code before it can adversely impact a customer. """
As long as laser power is modulated using a period of 100us, with a necessarily-integral pulse width of 1-99us, then it's not physically possible to support fractional power levels.
- Todo
- talk to Jason about changing modulation PERIOD to longer value (200us? 400? 1000?), OR whether pulse WIDTH can be in smaller unit (500ns? 100ns?)
◆ set_laser_power_require_modulation()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_power_require_modulation | ( | self, | |
| bool | flag ) |
◆ set_laser_tec_mode()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_tec_mode | ( | self, | |
| mode ) |
◆ set_laser_temperature_setpoint_raw()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_temperature_setpoint_raw | ( | self, | |
| int | value ) |
◆ set_laser_warning_delay_sec()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_warning_delay_sec | ( | self, | |
| value ) |
◆ set_laser_watchdog_sec()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_laser_watchdog_sec | ( | self, | |
| sec ) |
◆ set_log_level()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_log_level | ( | self, | |
| str | s ) |
◆ set_mod_delay_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_delay_us | ( | self, | |
| float | us ) |
◆ set_mod_duration_us_NOT_USED()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_duration_us_NOT_USED | ( | self, | |
| float | us ) |
◆ set_mod_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_enable | ( | self, | |
| bool | flag ) |
◆ set_mod_linked_to_integration()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_linked_to_integration | ( | self, | |
| bool | flag ) |
◆ set_mod_period_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_period_us | ( | self, | |
| float | us ) |
◆ set_mod_width_us()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_mod_width_us | ( | self, | |
| float | us ) |
◆ set_onboard_scans_to_average()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_onboard_scans_to_average | ( | self, | |
| n ) |
This is provided to let ENLIGHTEN *turn off* onboard averaging settings
which might have been generated, and (deliberately) left in place after
an Auto-Raman measurement.
◆ set_pixel_mode()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_pixel_mode | ( | self, | |
| float | mode ) |
- Parameters
-
mode integral value 0-3
mode  ADC (AD)   Pixel Width (OD)
b00   10-bit     10-bit
b01   10-bit     12-bit
b10   12-bit     10-bit
b11   12-bit     12-bit
◆ set_raman_delay_ms()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_raman_delay_ms | ( | self, | |
| int | ms ) |
◆ set_raman_mode_enable_NOT_USED()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_raman_mode_enable_NOT_USED | ( | self, | |
| bool | flag ) |
Enable "Raman mode" (automatic laser) in the spectrometer firmware.
◆ set_scans_to_average()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_scans_to_average | ( | self, | |
| n ) |
◆ set_selected_laser()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_selected_laser | ( | self, | |
| int | value ) |
On spectrometers supporting two lasers, select the primary (0) or
secondary (1).  Laser Enable, laser power etc should all then
affect the currently-selected laser.
@warning conflicts with GET_RAMAN_MODE_ENABLE
◆ set_shutter_open()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_shutter_open | ( | self, | |
| bool | flag ) |
◆ set_single_region()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_single_region | ( | self, | |
| int | n ) |
This function uses the the multi-region feature to select just a single
pre-configured region at a time.  Whichever region is selected, that
region's parameters are written to "region 0" of the spectrometer, and
the global wavecal is updated to use that region's calibration.

@todo consider clear_region() function to restore physical ROI to
    (0, active_vertical_pixels, 0, active_horizontal_pixels)
    (leave wavecal alone?)
◆ set_strobe_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_strobe_enable | ( | self, | |
| bool | flag ) |
this is a synonym for _set_laser_enable_immediate(), but without side-effects
◆ set_tec_enable()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_tec_enable | ( | self, | |
| bool | flag ) |
- Todo
- rename set_detector_tec_enable
◆ set_trigger_delay()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_trigger_delay | ( | self, | |
| float | half_us ) |
A confenurable delay from when an inbound trigger signal is
received by the spectrometer, until the triggered acquisition actually starts.

Default value is 0us.

Unit is in 0.5 microseconds (500ns), so value of 25 would represent 12.5us.

Value is 24bit, so max value is 16777216 (8.388608 sec).

Like triggering, only currently supported on ARM.
◆ set_trigger_source()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_trigger_source | ( | self, | |
| bool | value ) |
Set the source for incoming acquisition triggers.
@param value either 0 for "internal" or 1 for "external"
With internal triggering (the default), the spectrometer expects the
USB host to explicitly send a START_ACQUISITION (ACQUIRE) opcode to
begin each integration.  In external triggering, the spectrometer
waits for the rising edge on a signal connected to a pin on the OEM
accessory connector.
Technically on ARM, the microcontroller is continuously monitoring
both the external pin and listening for internal software opcodes.
On the FX2 you need to explicitly place the microcontroller into
external triggering mode to avail the feature.
◆ set_vertical_roi()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.set_vertical_roi | ( | self, | |
| roi ) |
◆ sync_acc_to_device()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.sync_acc_to_device | ( | self, | |
| arg ) |
XS Accessory.
◆ update_firmware_log()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.update_firmware_log | ( | self | ) |
◆ update_laser_watchdog()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.update_laser_watchdog | ( | self | ) |
Automatically set the laser watchdog long enough to handle the current
integration time, assuming we have to perform 6 throwaways on the sensor
in case it went to sleep.

@note we are not currently using this function
◆ update_vertical_roi()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.update_vertical_roi | ( | self | ) |
◆ write_eeprom()
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.write_eeprom | ( | self, | |
| arg ) |
Member Data Documentation
◆ allow_default_gain_reset
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.allow_default_gain_reset = True |
◆ area_scan_frame
| list wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.area_scan_frame = [ [0] * self.settings.pixels() for line in range(self.settings.eeprom.actual_pixels_vertical) ] |
◆ ccd_temperature_invalid
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.ccd_temperature_invalid = False |
◆ connected
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.connected = False |
◆ connecting
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.connecting = False |
◆ detector_tec_setpoint_degC
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.detector_tec_setpoint_degC = degC |
◆ detector_tec_setpoint_has_been_set
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.detector_tec_setpoint_has_been_set = False |
◆ device
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.device = None |
◆ device_type
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.device_type |
◆ extra_area_scan_data
| list wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.extra_area_scan_data = [] |
◆ has_received_spectrum
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.has_received_spectrum = False |
◆ imx385
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.imx385 = IMX385() |
◆ inject_random_errors
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.inject_random_errors = False |
◆ laser_temperature_invalid
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.laser_temperature_invalid = False |
◆ last_applied_laser_power
| float wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.last_applied_laser_power = 0.0 |
◆ last_spectrum
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.last_spectrum = None |
◆ last_usb_timestamp
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.last_usb_timestamp = None |
◆ next_applied_laser_power
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.next_applied_laser_power = None |
◆ prev_pixels
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.prev_pixels = None |
◆ raise_exceptions
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.raise_exceptions = False |
◆ random_error_perc
| float wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.random_error_perc = 0.001 |
◆ retry_enabled
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.retry_enabled = True |
◆ retry_max
| int wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.retry_max = 3 |
◆ retry_ms
| int wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.retry_ms = 5 |
◆ settings
| wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.settings = SpectrometerSettings(device_id) |
◆ shutdown_requested
| bool wasatch.FeatureIdentificationDevice.FeatureIdentificationDevice.shutdown_requested = False |
The documentation for this class was generated from the following file:
- wasatch/FeatureIdentificationDevice.py
Generated by
 1.13.2